About Me
My name is Zihan Zhu (朱紫涵). I’m currently a Direct Doctorate student at ETH Zurich in Computer Science, supervised by Prof. Marc Pollefeys and Prof. Andreas Geiger. I obtained my Bachelor degree at Zhejiang University. My research focuses on 3D computer vision, in particular building robust SLAM and 3D reconstruction systems for the real world.
🔥 News
- 2026.09: 🎉🎉 Our paper CLoSeR is accepted to NeurIPS 2026!
- 2026.09: 🏆🏆 Our paper on transparent object reconstruction received the Best Paper Honorable Mention Award of Computational Visual Media (CVM Journal Awards in 2025)!
- 2026.06: 🏆🏆 Our team ETH-THU-Stuttgart won 1st place in the Localization Task of the Hilti-Trimble SLAM Challenge 2026 (announced at ICRA 2026)!
- 2026.06: 🎉🎉 Our paper VIGS-SLAM is accepted to ECCV 2026!
- 2026.03: 🎉🎉 Two papers (DROID-W and WildPose) are accepted to CVPR 2026!
- 2025.02: 🎉🎉 Our paper WildGS-SLAM is accepted to CVPR 2025!
- 2024.03: 🎉🎉 Our paper NeRF On-the-go is accepted to CVPR 2024!
- 2023.03: 🏆🏆 NICER-SLAM received the Best Paper Honorable Mention Award at 3DV 2024!
- 2022.03: 🎉🎉 One paper conditionally accepted to SIGGRAPH 2022 (journal track)!
- 2022.03: 🎉🎉 I have been admitted to the Direct Doctorate programme in the ETH Zurich Department of Computer Science!
- 2022.03: 🎉🎉 Our paper NICE-SLAM is accepted to CVPR 2022!
📖 Educations
- 2022.09 - present, Direct Doctorate, Department of Computer Science, ETH Zurich, Zurich, Switzerland.
- 2018.09 - 2022.06, Undergraduate, Chu Kochen Honors College, Zhejiang Univeristy, Hangzhou, China.
📝 Publications
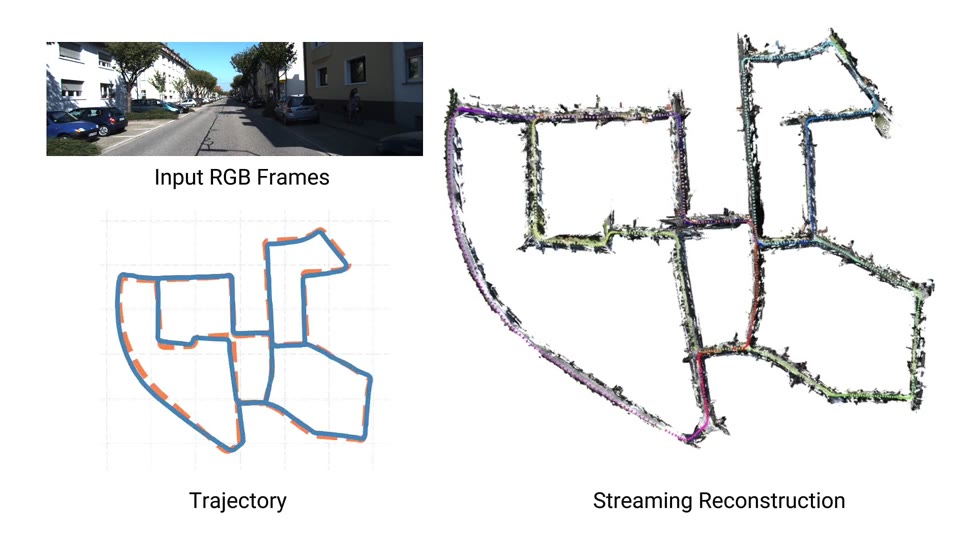
CLoSeR: Closing the Loop for Long-Context Streaming Reconstruction Zihan Zhu*, Moyang Li*, Wei Zhang, Marc Pollefeys, Dániel Béla Baráth
NeurIPS, 2026 | Project | arXiv | Code
- Bringing loop closure to feed-forward streaming reconstruction, removing drift at kilometer scale.
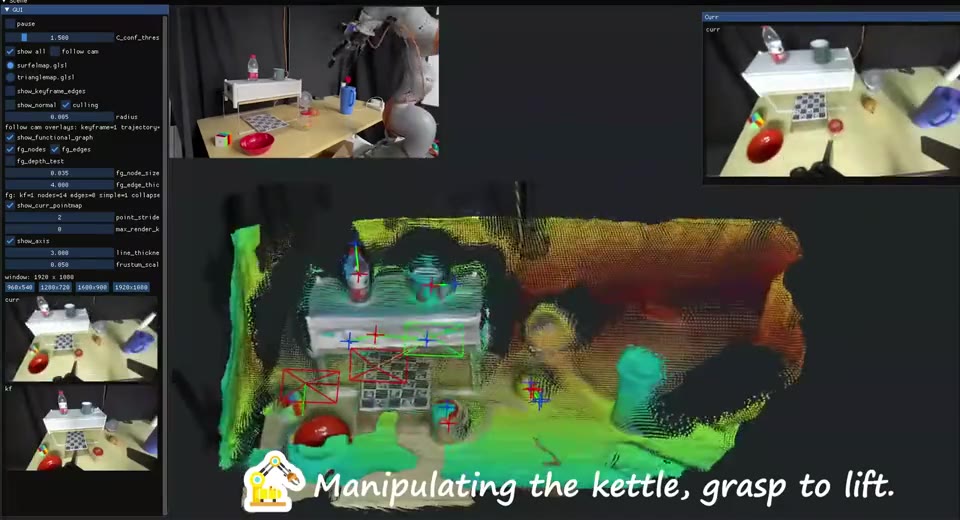
Functional-SLAM: Interaction-Aware Mapping with Online Functional Scene Graphs Xinggang Hu, Chenyangguang Zhang, Zihan Zhu, Ruida Zhang, Xiangkui Zhang, Xiangyang Ji
CoRL, 2026 | arXiv | Code | Video
- Interaction-aware SLAM that builds functional scene graphs online.
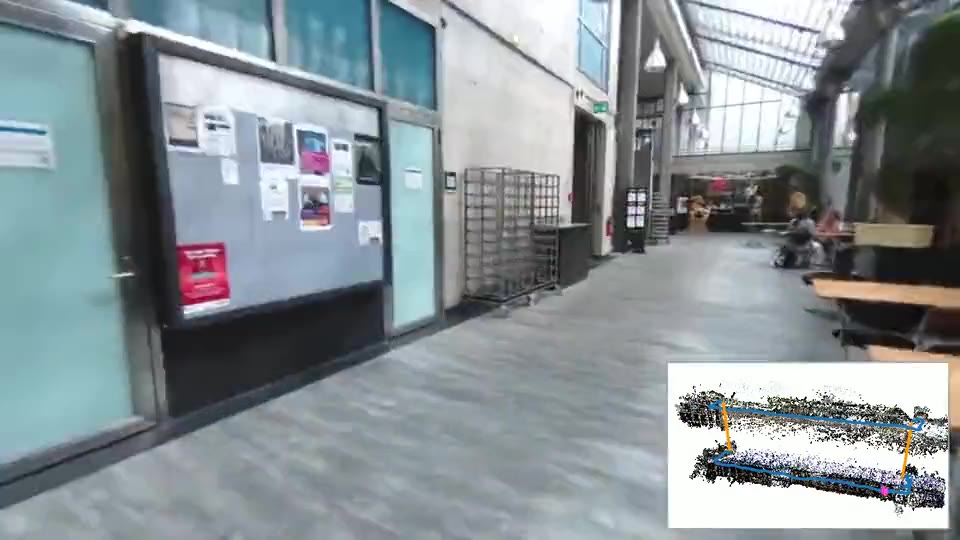
Elevator-VIGS: Separating Elevator Motion from Robot Motion in Visual-Inertial Gaussian Splatting SLAM Rui Zhou*, Zihan Zhu*, Wei Zhang, Zizhou Luo, Norbert Haala, Marc Pollefeys
arXiv, 2026 | Project | arXiv | Code
- Visual-inertial Gaussian Splatting SLAM that stays robust when the robot rides in elevators.
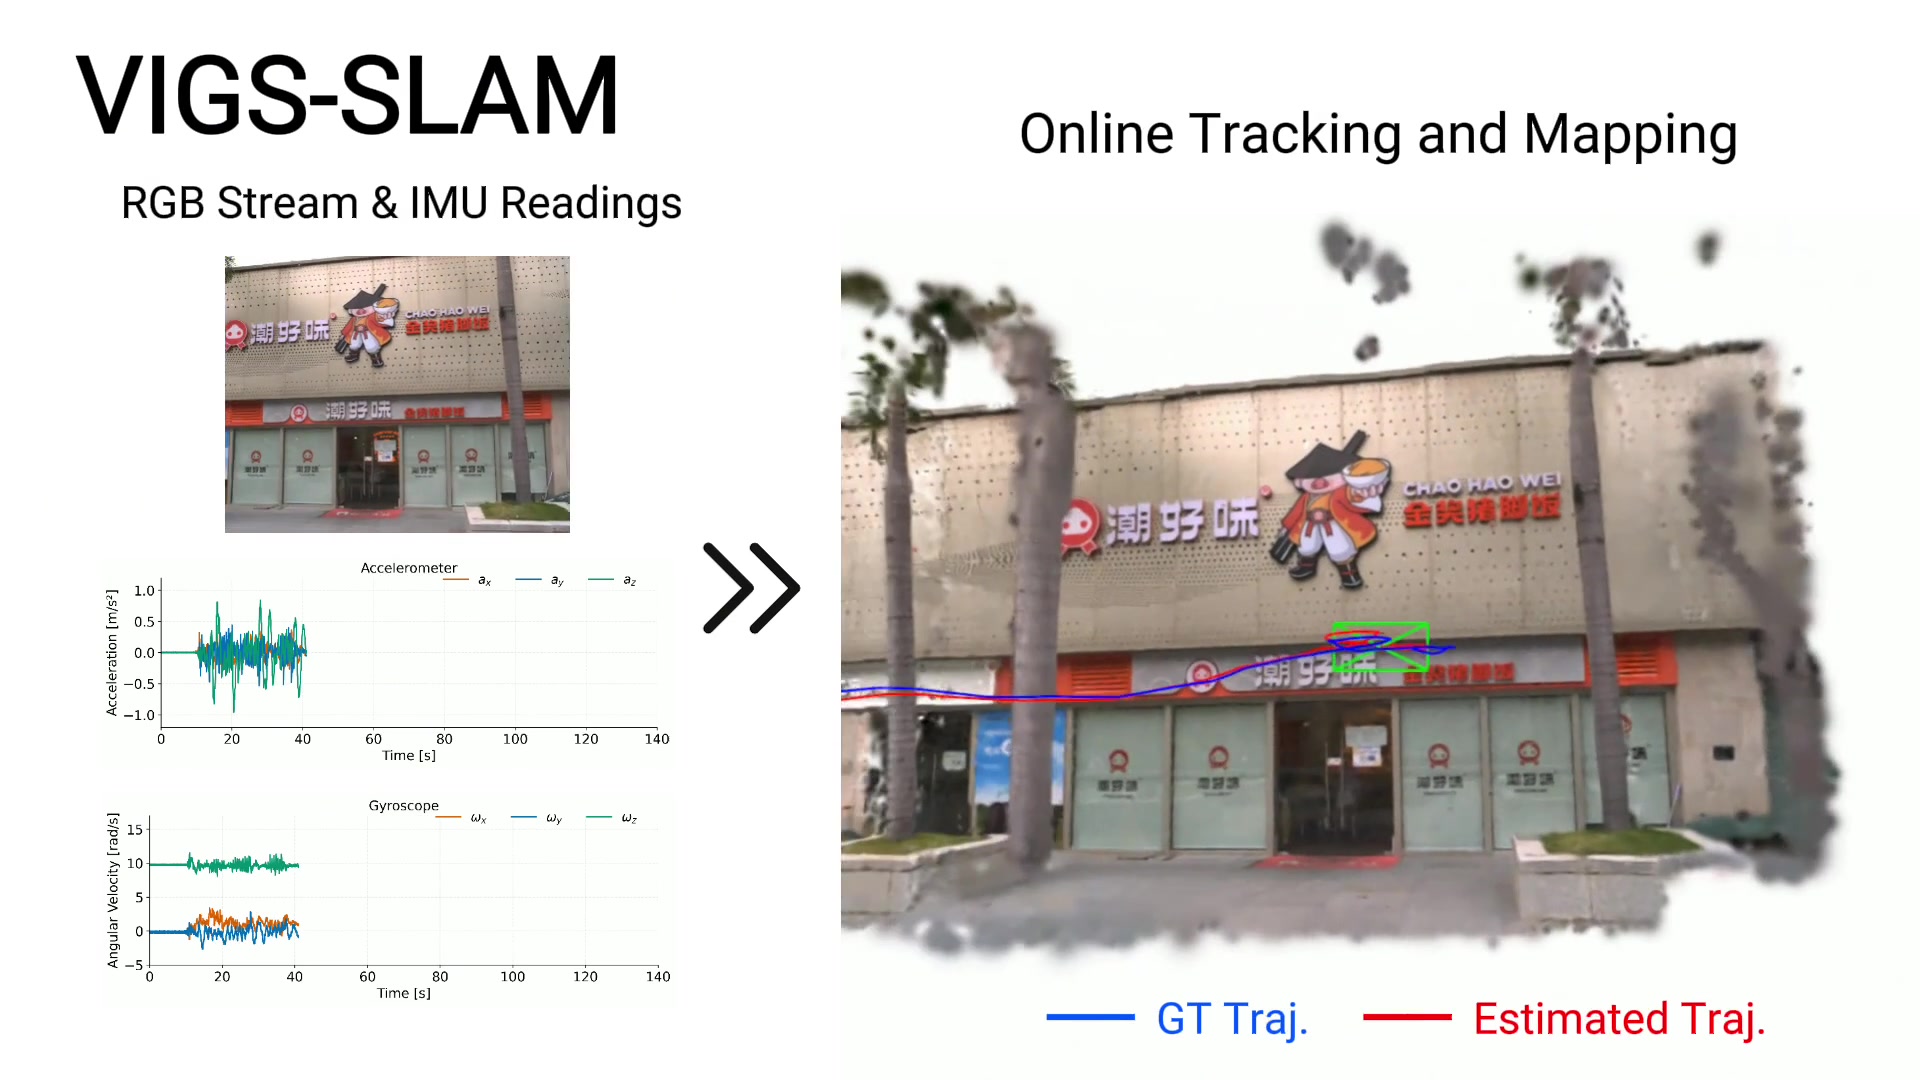
VIGS-SLAM: Visual Inertial Gaussian Splatting SLAM Zihan Zhu, Wei Zhang, Moyang Li, Norbert Haala, Marc Pollefeys, Dániel Béla Baráth
ECCV, 2026 | Project | arXiv | Code
- Visual inertial Gaussian Splatting SLAM for robust and accurate localization and mapping.
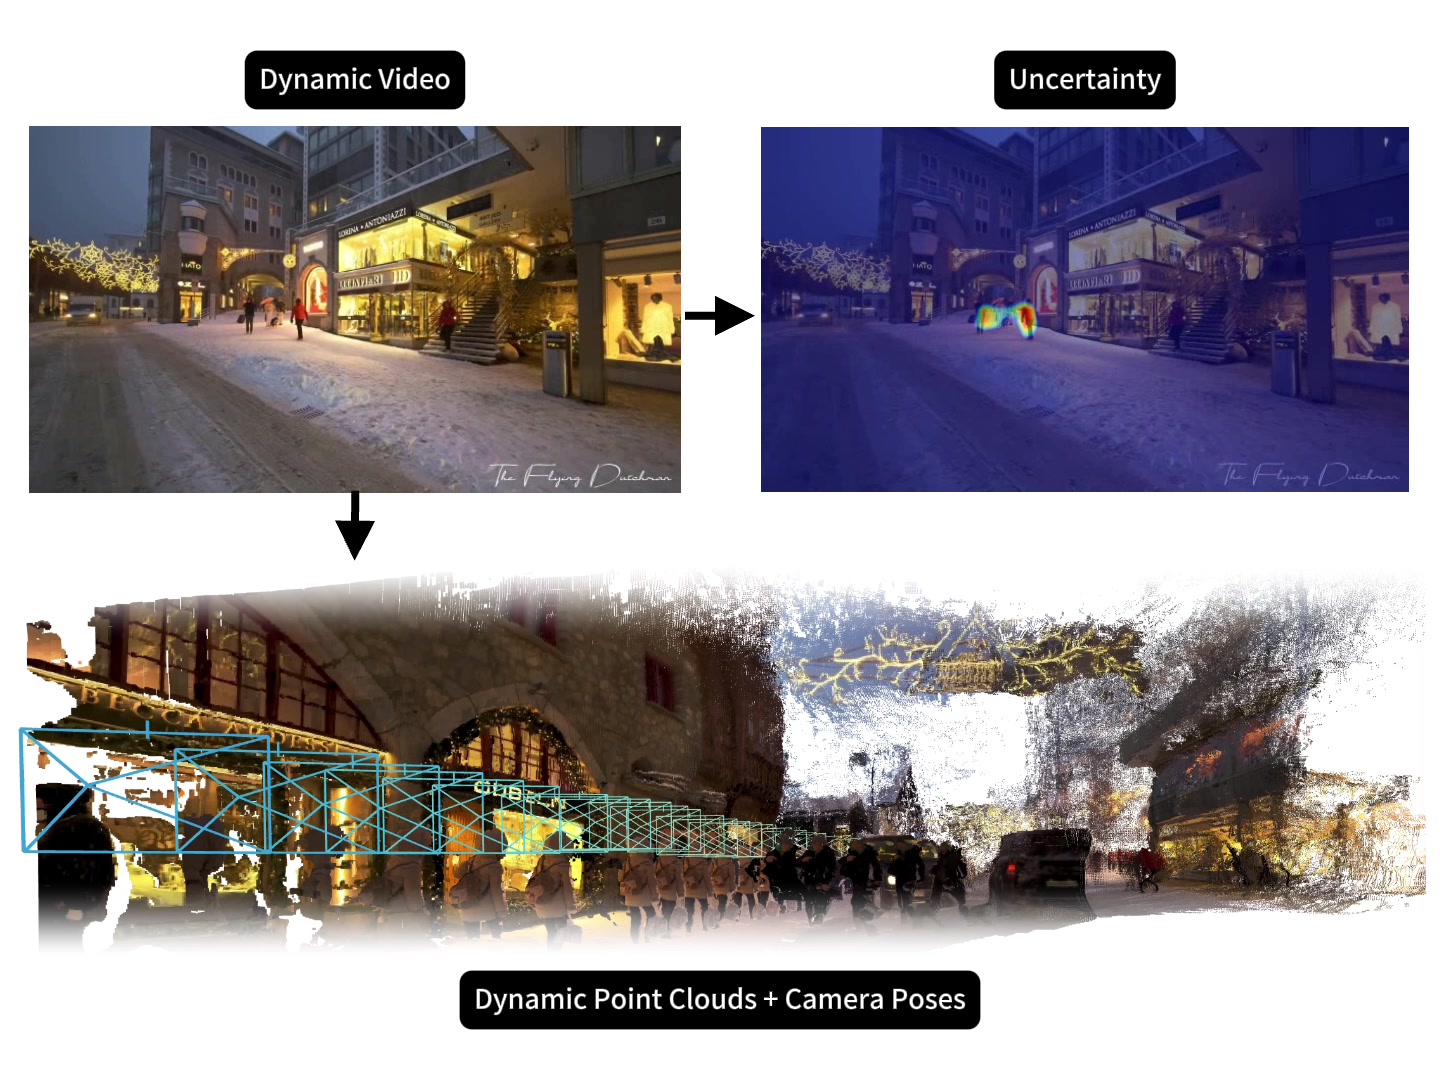
DROID-W: DROID-SLAM in the Wild Moyang Li*, Zihan Zhu*, Marc Pollefeys, Dániel Béla Baráth
CVPR, 2026 | Project | arXiv | Code
- Extending DROID-SLAM to handle in-the-wild scenes with dynamic objects and appearance changes.
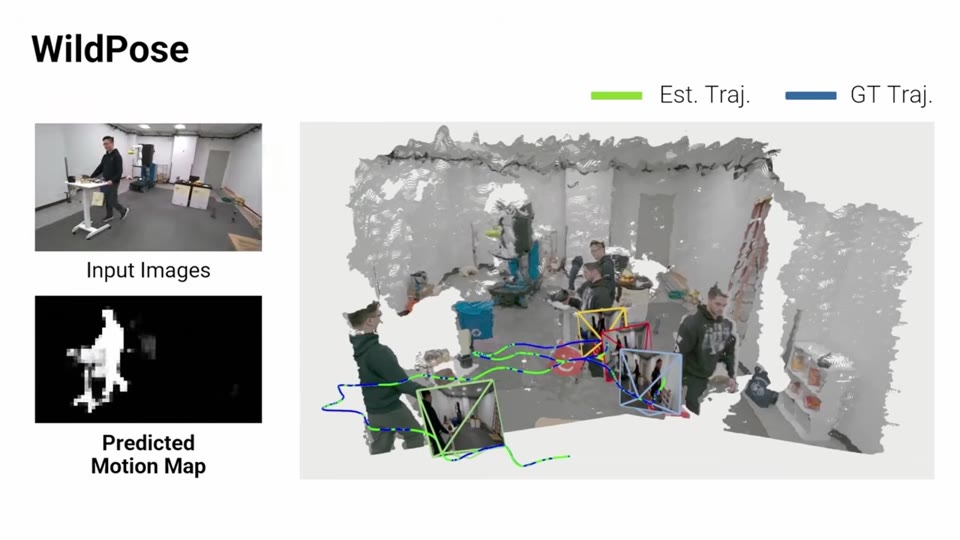
WildPose: A Unified Framework for Robust Pose Estimation in the Wild Jianhao Zheng, Liyuan Zhu, Zihan Zhu, Iro Armeni
CVPR, 2026 | Project | arXiv | Code
- A unified camera pose estimator that is robust in both dynamic and static scenes.
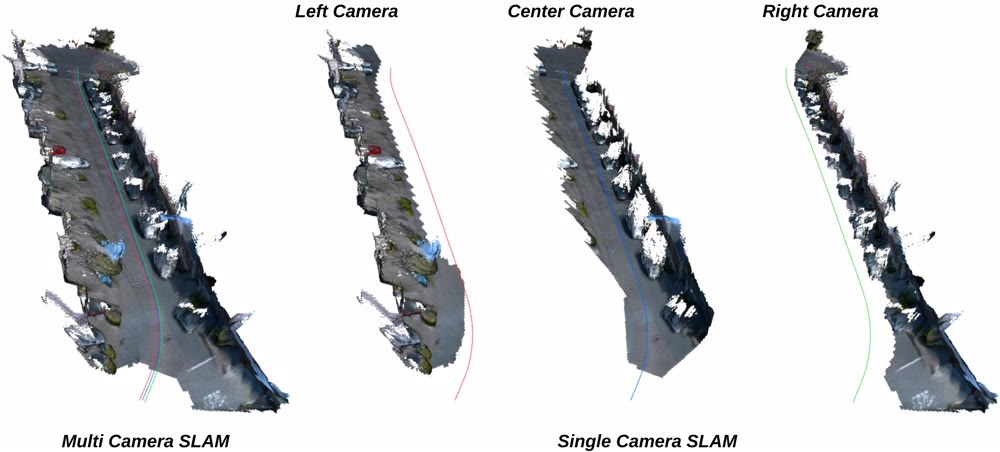
MCGS-SLAM: A Multi-Camera SLAM Framework Using Gaussian Splatting for High-Fidelity Mapping Zhihao Cao, Hanyu Wu, Li Wa Tang, Zizhou Luo, Wei Zhang, Marc Pollefeys, Zihan Zhu, Martin R Oswald
ICRA, 2026 | Project | arXiv | Code
- RGB-only multi-camera Gaussian Splatting SLAM for high-fidelity mapping.
WildGS-SLAM: Monocular Gaussian Splatting SLAM in Dynamic Environments Jianhao Zheng*, Zihan Zhu*, Valentin Bieri, Marc Pollefeys, Songyou Peng, Iro Armeni
CVPR, 2025 | Project | arXiv | Code
- Monocular Gaussian Splatting SLAM that robustly handles dynamic environments.
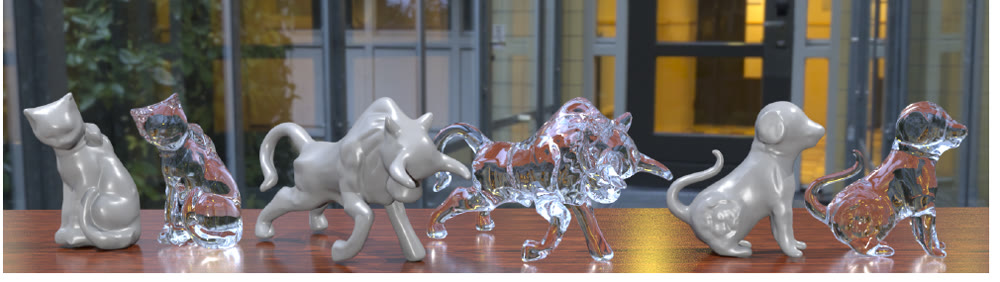
A Hybrid Mesh-neural Representation for 3D Transparent Object Reconstruction Jiamin Xu, Zihan Zhu, Hujun Bao, Weiwei Xu
Computational Visual Media (CVM), 2025 (Best Paper Honorable Mention Award) | Paper | arXiv | Code
- Reconstructing transparent objects from handheld captures under natural lighting.
NeRF On-the-go Exploiting Uncertainty for Distractor-free NeRFs in the Wild Weining Ren*, Zihan Zhu*, Boyang Sun, Jiaqi Chen, Marc Pollefeys, Songyou Peng
CVPR, 2024 | Project | arXiv | Code
- We enable robust novel view synthesis from casually captured in-the-wild images.
NICER-SLAM: Neural Implicit Scene Encoding for RGB SLAM Zihan Zhu*, Songyou Peng*, Viktor Larsson, Zhaopeng Cui, Martin R Oswald, Andreas Geiger, Marc Pollefeys
3DV, 2024 (Oral, Best Paper Honorable Mention Award) | Project | arXiv | Code
- RGB-only version of our NICE-SLAM, making it NICER.
Scalable Neural Indoor Scene Rendering Xiuchao Wu*, Jiamin Xu*, Zihan Zhu, Hujun Bao, Qixing Huang, James Tompkin, Weiwei Xu
ACM Transactions on Graphics (TOG) 41, 4 (SIGGRAPH 2022) | Project | Code
- A scalable neural scene reconstruction and rendering method to support distributed training and interactive rendering of large indoor scenes.
NICE-SLAM: Neural Implicit Scalable Encoding for SLAM Zihan Zhu*, Songyou Peng*, Viktor Larsson, Weiwei Xu, Hujun Bao, Zhaopeng Cui, Martin R Oswald, Marc Pollefeys
CVPR, 2022 | Project | arXiv | Code
- A neural implicit-based RGB-D SLAM that can be applied to large-scale scenes.
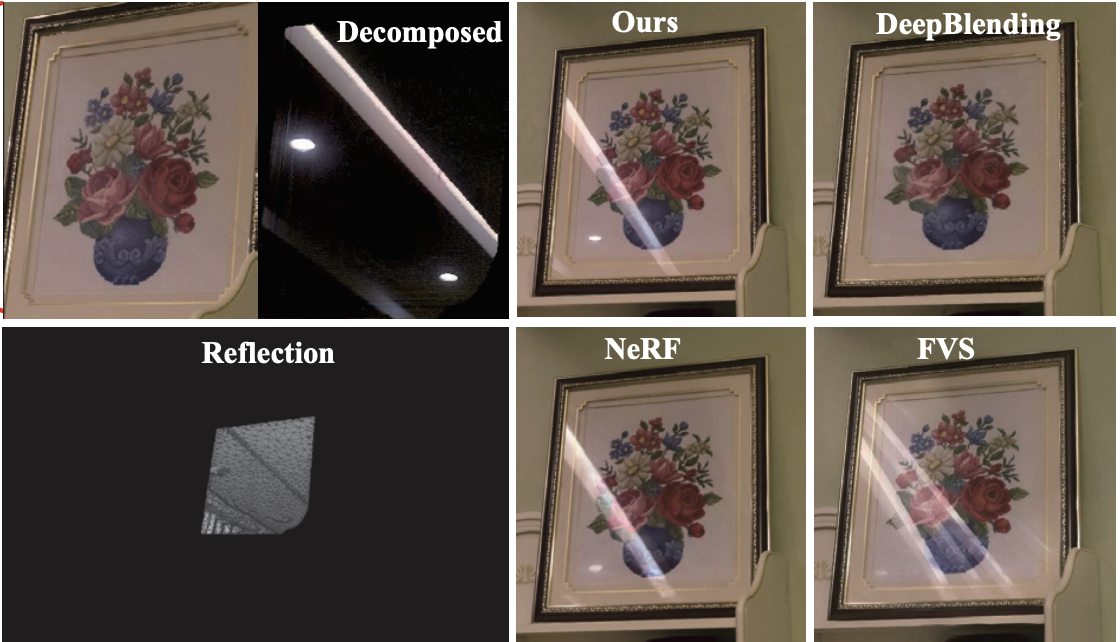
Scalable Image-based Indoor Scene Rendering with Reflections Jiamin Xu, Xiuchao Wu, Zihan Zhu, Qixing Huang, Yin Yang, Hujun Bao, Weiwei Xu
ACM Transactions on Graphics (TOG) 40, 4 (SIGGRAPH 2021) | Paper
- An image-based rendering method that can be applied to large-scale indoor scenes with reflections.
🎖 Honors and Awards
- 2026: 1st place, Localization Task, Hilti-Trimble SLAM Challenge 2026
- 2026: Best Paper Honorable Mention Award, CVM Journal Awards in 2025 (Hybrid Mesh-neural Representation for 3D Transparent Object Reconstruction)
- 2024: Best Paper Honorable Mention Award, 3DV 2024 (NICER-SLAM)
💻 Academic Services
Conference Reviewer: CVPR, ICCV, ECCV, NeurIPS, IROS, ICRA, SIGGRAPH, SIGGRAPH Asia, 3DV
Journal Reviewer: T-RO, RA-L, TVCG, TPAMI, IJCV